Par DAMIAO
DAMIAO DM-J10422P-2EC 100Nm Planetary Joint Servo Motor Dual Encoder Gear Motor
$451.94 - $459.71
Taxes incluses.
Frais d'expédition calculés à l'étape de paiement.
Prix habituel
$451.94
Prix habituel
Prix soldé
$451.94
Prix unitaire
par
Impossible de charger la disponibilité du service de retrait
Availability:
2000 en stock
SKU:
106105
Tags:
Collections:

Prix habituel
$451.94
Prix habituel
Prix soldé
$451.94
Available Options:
* Option 1: Motor + USB-to-CAN Module
* Option 2: Motor + USB-to-CAN FD Module
* Option 3: Motor + USB-to-CAN FD Module (With Housing)
Advantages:
* Max Stall Torque 400N·m
* Built-in High-Precision Inductive Encoder
* Hollow Shaft Hole
* Supports CAN FD
* Four Modes
* Dual Temperature Protection
* Dual Inductive Encoders
Features:
* Dual Encoders with Single-Turn Absolute Positioning: Features dual encoders and single-turn absolute position detection at the output shaft. The absolute position information is retained even after power loss.
* Integrated Motor and Driver Design: Combines the motor and driver in a compact, highly integrated design.
* PC-Based Visual Debugging and CAN Parameter Access: Supports graphical debugging via PC software and parameter reading and writing over CAN.
* CAN FD Support: Supports CAN FD communication with a maximum baud rate of 5Mbps.
* Real-Time Motor Status Feedback: Provides motor speed, position, torque, motor temperature, and other status information via the CAN bus.
* Dual Temperature Protection: Features dual temperature protection for enhanced operational safety.
* CAN-Based Firmware Updates: Supports firmware updates via the CAN bus.
Specifications:
Motor Parameters:
* Rated Voltage: 48V
* Rated Phase Current/Supply Current: 44.5A/27.5A
* Peak Phase Current/Supply Current: 165.0A /48.9A
* Rated Torque: 100.0Nm
* Peak Torque: 400.0Nm
* Rated Speed: 100rpm
* Maximum No-Load Speed: 120rpm
Motor Characteristic Values:
* Number of Slots: 36
* Number of Pole Pairs: 16
* Gear Reduction Ratio: 1:22
* Phase Inductance: 38μH (at 25°C)
* Phase Resistance: 81mΩ (at 25°C)
Structure and Weight:
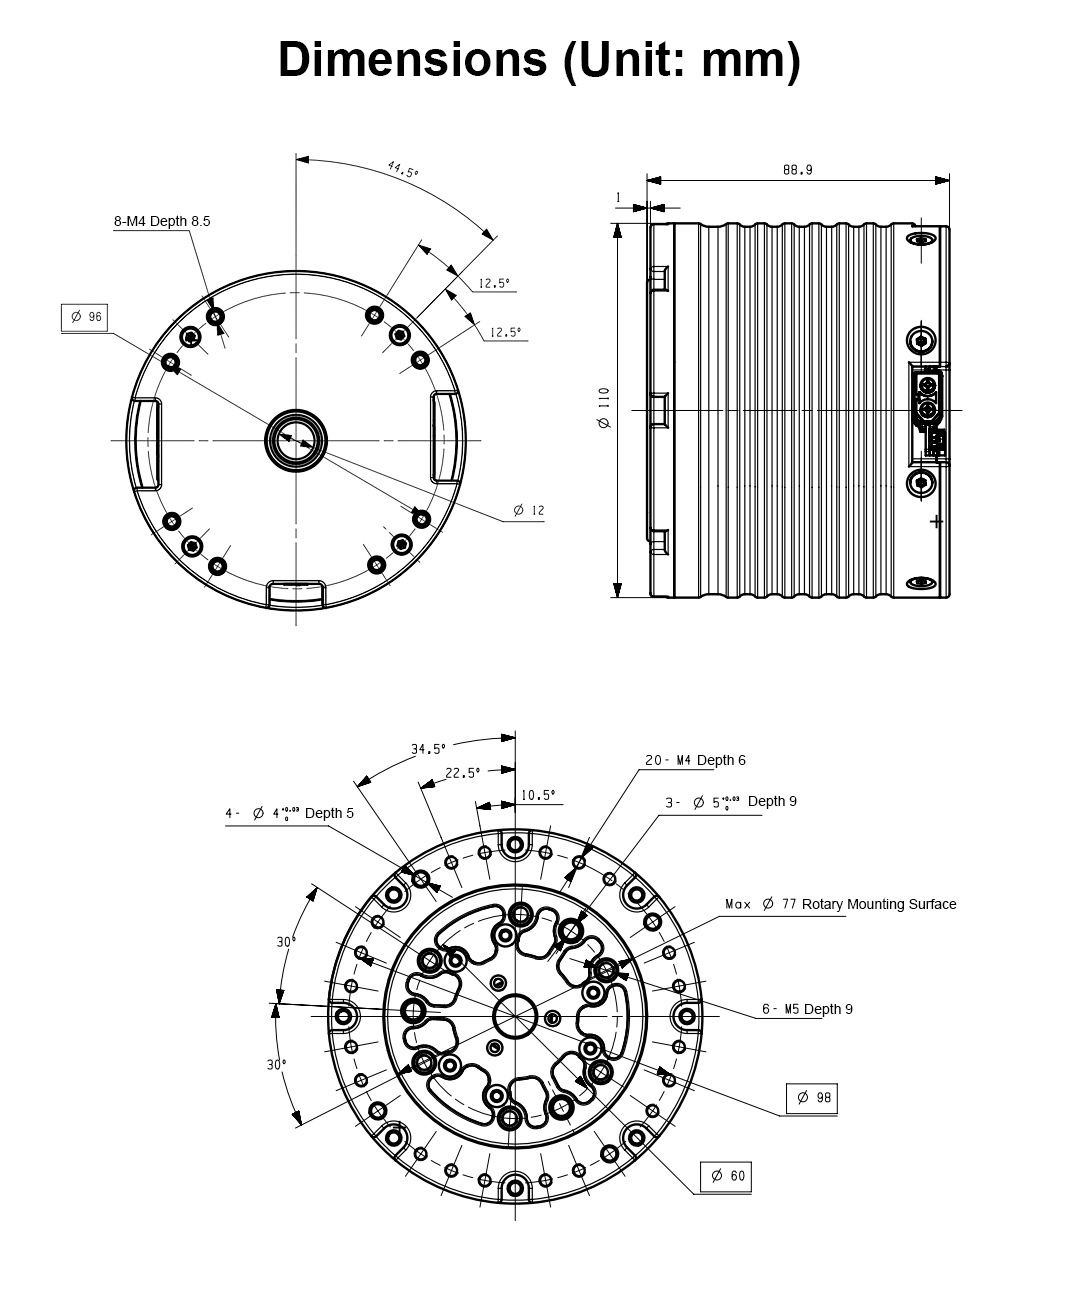
* Center Bore Diameter: 12mm
* Outer Diameter: 110mm
* Height: 88.9mm
* Motor Weight: Approx. 2700g
Encoder:
* Encoder Resolution: 17-bit
* Encoder Accuracy: ±0.03°
* Number of Encoders: 2
Communication:
* Control Interface: CAN at 5Mbps (Max.)
* Parameter Tuning Interface: UART at 921600bps
Control:
* Control Modes: MIT Mode, Velocity Mode, Position Mode, and Hybrid Force-Position Mode
Protection Functions:
* Driver Over-temperature Protection: Protection temperature: 120°C. The motor exits Enable Mode when the driver temperature exceeds the protection threshold.
* Motor Over-temperature Protection: Configurable according to application requirements. A temperature limit of no more than 100°C is recommended. Setting the limit above 110°C may cause the motor windings to burn out. The motor exits Enable Mode when the over-temperature threshold is reached.
* Motor Overvoltage Protection: Configurable according to application requirements. A voltage limit of no more than 65V is recommended. The motor exits Enable Mode when an overvoltage condition occurs.
* Communication Loss Protection: The motor automatically exits Enable Mode if no CAN command is received within the configured timeout period.
* Motor Over-current Protection: Configurable according to application requirements. A setting of no more than 0.98 is recommended. The motor exits Enable Mode when an over-current condition occurs.
* Motor Under-voltage Protection: The motor exits Enable Mode if the supply voltage falls below the configured threshold. The supply voltage must not be lower than 20V.
Packing List:
Option 1: Motor + USB-to-CAN Module
* DM-J10422P-2EC Motor (Power Supply: 24V-48V) x 1
* GH1.25 3-Pin Cable (300mm, Opposite-Side Connector) x 1
* GH1.25 2-Pin Cable (300mm, Opposite-Side Connector) x 1
* XT60 Dual-Ended Cable (200mm) x 1
* USB-to-CAN Module for Debugging x 1
* GH1.25 3-Pin Cable (300mm, Opposite-Side Connector) for Debugging x 1
* GH1.25 2-Pin Cable (300mm, Opposite-Side Connector) for Debugging x 1
* USB Type-A to USB Type-C 2.0 Data Cable for Debugging x 1
Packaging Details:
* Package weight: 2.85kg